
Minimum Time to Visit a Cell In a Grid
HardPrompt
You are given a m x n matrix grid consisting of non-negative integers where grid[row][col] represents the minimum time required to be able to visit the cell (row, col), which means you can visit the cell (row, col) only when the time you visit it is greater than or equal to grid[row][col].
You are standing in the top-left cell of the matrix in the 0th second, and you must move to any adjacent cell in the four directions: up, down, left, and right. Each move you make takes 1 second.
Return the minimum time required in which you can visit the bottom-right cell of the matrix. If you cannot visit the bottom-right cell, then return -1.
Example 1:
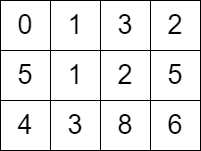
Input: grid = [[0,1,3,2],[5,1,2,5],[4,3,8,6]]
Output: 7
Explanation: One of the paths that we can take is the following:
- at t = 0, we are on the cell (0,0).
- at t = 1, we move to the cell (0,1). It is possible because grid[0][1] <= 1.
- at t = 2, we move to the cell (1,1). It is possible because grid[1][1] <= 2.
- at t = 3, we move to the cell (1,2). It is possible because grid[1][2] <= 3.
- at t = 4, we move to the cell (1,1). It is possible because grid[1][1] <= 4.
- at t = 5, we move to the cell (1,2). It is possible because grid[1][2] <= 5.
- at t = 6, we move to the cell (1,3). It is possible because grid[1][3] <= 6.
- at t = 7, we move to the cell (2,3). It is possible because grid[2][3] <= 7.
The final time is 7. It can be shown that it is the minimum time possible.
Example 2:
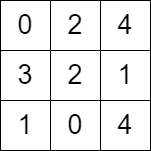
Input: grid = [[0,2,4],[3,2,1],[1,0,4]]
Output: -1
Explanation: There is no path from the top left to the bottom-right cell.
Constraints:
m == grid.lengthn == grid[i].length2 <= m, n <= 10004 <= m * n <= 1050 <= grid[i][j] <= 105grid[0][0] == 0
Approaches
2 approaches with complexity analysis and trade-offs.
This problem can be modeled as finding the shortest path in a state graph where states are (time, row, col). A BFS-like approach, similar to the Shortest Path Faster Algorithm (SPFA), can solve it by using a regular queue instead of a priority queue. While simpler in concept, this approach can be inefficient because it might explore paths that are clearly not optimal early on, leading to re-visiting and re-processing cells multiple times. In the worst-case scenario, its time complexity is much higher than Dijkstra's algorithm, making it unsuitable for large grids.
Algorithm
- Initialize a
distarray with infinity anddist[0][0] = 0. - Create a standard queue and add the starting state
(0, 0, 0). - While the queue is not empty:
- Dequeue a state
(t, r, c). - For each neighbor
(nr, nc):- Calculate the earliest possible arrival time
new_timebased on the current timet, the grid constraintgrid[nr][nc], and parity rules. - This calculation must also check if waiting is possible (i.e., if there's a 'helper' neighbor accessible at time
t+1). - If
new_timeis better thandist[nr][nc], updatedist[nr][nc]and enqueue(new_time, nr, nc).
- Calculate the earliest possible arrival time
- Dequeue a state
- After the loop,
dist[m-1][n-1]holds the result.
Walkthrough
The core idea is to maintain an array dist[m][n] storing the minimum time to reach each cell. We start at (0,0) at time 0 and use a standard queue to perform the search. Each element in the queue will be a tuple (time, row, col).
When we extract a cell (r, c) reached at time t from the queue, we explore its neighbors. For each neighbor (nr, nc):
- A direct move is possible if we can arrive at
t+1without violating the grid's time constraint, i.e.,t + 1 >= grid[nr][nc]. The new time at(nr, nc)would bet + 1. - If a direct move is not possible (
t + 1 < grid[nr][nc]), we must wait. Waiting involves moving back and forth between the current cell(r, c)and an adjacent 'helper' cell. This is only possible if there's at least one neighbor(or, oc)of(r, c)that can be visited at timet + 1(i.e.,t + 1 >= grid[or][oc]). - If waiting is possible, the arrival time at
(nr, nc)must be at leastgrid[nr][nc]and also have a different parity from the departure timet(since any path from(r,c)to(nr,nc)takes an odd number of steps). The minimum such time is calculated. - If we find a path to a neighbor
(nr, nc)with a new time that is less than the currently knowndist[nr][nc], we update the distance and add the new state(new_time, nr, nc)to the queue.
Since we use a regular queue, we are not guaranteed to process the cell with the minimum time first. This can lead to a cell being enqueued multiple times if shorter paths are found later, which is the main reason for the potential inefficiency.
Complexity
Time
O((m*n)^2) in the worst case. Each of the V = m*n vertices can be enqueued up to V times, and for each dequeue, we check E (at most 4) edges.
Space
O(m*n) for the `dist` array and the queue, which in the worst case could hold many states for each cell.
Trade-offs
Pros
Conceptually simpler as it avoids the use of a priority queue.
Cons
Inefficient for this problem, with a worst-case time complexity that is too high for the given constraints.
Likely to result in a 'Time Limit Exceeded' error on competitive programming platforms.
A correct implementation requires the same complex logic as the Dijkstra approach, negating its main advantage of simplicity.
This problem is a variation of the shortest path problem on a grid. Dijkstra's algorithm is perfectly suited for this, as it efficiently finds the shortest paths from a single source in a graph with non-negative edge weights. Here, the 'weight' or 'cost' to travel between cells is not constant; it depends on the arrival time at the current cell and the time constraint of the destination cell. We use a priority queue to always expand the search from the cell that is reachable in the minimum amount of time. This ensures that the first time we reach any cell, it is via the fastest possible path, so we only need to process each cell once.
Algorithm
- Initialize a
distarray with infinity anddist[0][0] = 0. - Create a priority queue ordered by time and add the starting state
(0, 0, 0). - While the priority queue is not empty:
- Dequeue the state
(t, r, c)with the minimum time. - If this path is suboptimal (
t > dist[r][c]), skip. - If it's the destination, return
t. - For each neighbor
(nr, nc):- Calculate the earliest possible arrival time
new_timebased ont,grid[nr][nc], and parity rules. This calculation must account for whether a direct move is possible or if waiting is required and feasible. - If
new_timeis better thandist[nr][nc], updatedist[nr][nc]and add(new_time, nr, nc)to the priority queue.
- Calculate the earliest possible arrival time
- Dequeue the state
- If the loop finishes, the destination is unreachable, so return -1.
Walkthrough
The algorithm maintains a dist array to store the minimum time to reach each cell, initialized to infinity. A priority queue stores tuples of (time, row, col), ordered by time.
We start by pushing (0, 0, 0) to the priority queue. Then, we repeatedly extract the state with the smallest time.
For a cell (r, c) reached at time t:
- If
tis greater than the already recordeddist[r][c], we skip it, as we've found a better path already. - If
(r, c)is the destination, we have found the minimum time and can returnt. - We then consider moving to each neighbor
(nr, nc). The key is calculating the new arrival timenew_time. The logic for this is as follows:- If
t + 1 >= grid[nr][nc], a direct move is possible. The arrival time is simplyt + 1. - If
t + 1 < grid[nr][nc], we must wait. The arrival time must be at leastgrid[nr][nc]. Furthermore, the time elapsed (new_time - t) must be an odd number of seconds. This meansnew_timeandtmust have different parity. The minimumnew_timeisgrid[nr][nc]if(grid[nr][nc] - t)is odd, orgrid[nr][nc] + 1if(grid[nr][nc] - t)is even.
- If
- This waiting is only possible if we can actually make moves to pass the time. This requires a 'helper' neighbor we can visit at
t+1. If no such neighbor exists, we are stuck and cannot move to(nr, nc)if it requires waiting. - If a valid
new_timeis calculated and it's less thandist[nr][nc], we updatedist[nr][nc]and push(new_time, nr, nc)to the priority queue.
If the priority queue becomes empty and we haven't reached the destination, it's unreachable, and we return -1.
import java.util.Arrays;import java.util.PriorityQueue; class Solution { public int minimumTime(int[][] grid) { int m = grid.length; int n = grid[0].length; // A crucial edge case: if we cannot move from the start, it's impossible. if (grid[0][1] > 1 && grid[1][0] > 1) { return -1; } int[][] dist = new int[m][n]; for (int[] row : dist) { Arrays.fill(row, Integer.MAX_VALUE); } // PriorityQueue stores {time, row, col} PriorityQueue<int[]> pq = new PriorityQueue<>((a, b) -> a[0] - b[0]); dist[0][0] = 0; pq.offer(new int[]{0, 0, 0}); int[][] dirs = {{0, 1}, {0, -1}, {1, 0}, {-1, 0}}; while (!pq.isEmpty()) { int[] curr = pq.poll(); int t = curr[0]; int r = curr[1]; int c = curr[2]; if (t > dist[r][c]) { continue; } if (r == m - 1 && c == n - 1) { return t; } for (int[] dir : dirs) { int nr = r + dir[0]; int nc = c + dir[1]; if (nr >= 0 && nr < m && nc >= 0 && nc < n) { int newTime; int requiredTime = grid[nr][nc]; if (t + 1 >= requiredTime) { newTime = t + 1; } else { int diff = requiredTime - t; if (diff % 2 == 0) { // Same parity, need an extra step newTime = requiredTime + 1; } else { // Different parity, can arrive exactly at requiredTime newTime = requiredTime; } } if (newTime < dist[nr][nc]) { dist[nr][nc] = newTime; pq.offer(new int[]{newTime, nr, nc}); } } } } return -1; }}Note: The provided code snippet simplifies the logic by assuming that if waiting is needed, it is always possible. This is not always true. A fully correct solution would need to check for a valid 'helper' neighbor at every step before calculating times for neighbors that require waiting. The initial check for the start node (0,0) handles the most common failure case for this simplified logic.
Complexity
Time
O(m*n * log(m*n)). The number of vertices V is m*n and edges E is at most 4*m*n. Each vertex is processed once. Priority queue operations (offer and poll) take O(log V) time.
Space
O(m*n) to store the `dist` array and the elements in the priority queue.
Trade-offs
Pros
Guaranteed to find the minimum time due to the nature of Dijkstra's algorithm.
Efficient, with a time complexity suitable for the problem's constraints.
Cons
Slightly more complex to implement than a standard BFS due to the priority queue.
The logic for calculating the time to the next cell is non-trivial and requires careful handling of the waiting mechanism and parity.
Solutions
Solution
class Solution {public int minimumTime(int[][] grid) { if (grid[0][1] > 1 && grid[1][0] > 1) { return -1; } int m = grid.length, n = grid[0].length; int[][] dist = new int[m][n]; for (var e : dist) { Arrays.fill(e, 1 << 30); } dist[0][0] = 0; PriorityQueue<int[]> pq = new PriorityQueue<>((a, b)->a[0] - b[0]); pq.offer(new int[]{0, 0, 0}); int[] dirs = {-1, 0, 1, 0, -1}; while (true) { var p = pq.poll(); int i = p[1], j = p[2]; if (i == m - 1 && j == n - 1) { return p[0]; } for (int k = 0; k < 4; ++k) { int x = i + dirs[k], y = j + dirs[k + 1]; if (x >= 0 && x < m && y >= 0 && y < n) { int nt = p[0] + 1; if (nt < grid[x][y]) { nt = grid[x][y] + (grid[x][y] - nt) % 2; } if (nt < dist[x][y]) { dist[x][y] = nt; pq.offer(new int[]{nt, x, y}); } } } } }}function minimumTime ( grid ) { if ( grid [ 0 ][ 1 ] > 1 && grid [ 1 ][ 0 ] > 1 ) return - 1 ; const [ m , n ] = [ grid . length , grid [ 0 ]. length ]; const DIRS = [ - 1 , 0 , 1 , 0 , - 1 ]; const q = new MinPriorityQueue ({ priority : ([ x ]) => x }); const dist = Array . from ({ length : m }, () => new Array ( n ). fill ( Number . POSITIVE_INFINITY )); dist [ 0 ][ 0 ] = 0 ; q . enqueue ([ 0 , 0 , 0 ]); while ( true ) { const [ t , i , j ] = q . dequeue (). element ; if ( i === m - 1 && j === n - 1 ) return t ; for ( let k = 0 ; k < 4 ; k ++ ) { const [ x , y ] = [ i + DIRS [ k ], j + DIRS [ k + 1 ]]; if ( x < 0 || x >= m || y < 0 || y >= n ) continue ; let nt = t + 1 ; if ( nt < grid [ x ][ y ]) { nt = grid [ x ][ y ] + (( grid [ x ][ y ] - nt ) % 2 ); } if ( nt < dist [ x ][ y ]) { dist [ x ][ y ] = nt ; q . enqueue ([ nt , x , y ]); } } } }class Solution {public: int minimumTime(vector<vector<int>> &grid) { if (grid[0][1] > 1 && grid[1][0] > 1) { return -1; } int m = grid.size(), n = grid[0].size(); int dist[m][n]; memset(dist, 0x3f, sizeof dist); dist[0][0] = 0; using tii = tuple<int, int, int>; priority_queue<tii, vector<tii>, greater<tii>> pq; pq.emplace(0, 0, 0); int dirs[5] = {-1, 0, 1, 0, -1}; while (1) { auto [t, i, j] = pq.top(); pq.pop(); if (i == m - 1 && j == n - 1) { return t; } for (int k = 0; k < 4; ++k) { int x = i + dirs[k], y = j + dirs[k + 1]; if (x >= 0 && x < m && y >= 0 && y < n) { int nt = t + 1; if (nt < grid[x][y]) { nt = grid[x][y] + (grid[x][y] - nt) % 2; } if (nt < dist[x][y]) { dist[x][y] = nt; pq.emplace(nt, x, y); } } } } }};class Solution: def minimumTime(self, grid: List[List[int]]) -> int: if grid[0][1] > 1 and grid[1][0] > 1: return - 1 m, n = len(grid), len(grid[0]) dist = [[inf] * n for _ in range(m)] dist[0][0] = 0 q = [(0, 0, 0)] dirs = (- 1, 0, 1, 0, - 1) while 1: t, i, j = heappop(q) if i == m - 1 and j == n - 1: return t for a, b in pairwise(dirs): x, y = i + a, j + b if 0 <= x < m and 0 <= y < n: nt = t + 1 if nt < grid[x][y]: nt = grid[x][y] + (grid[x][y] - nt) % 2 if nt < dist[x][y]: dist[x][y] = nt heappush(q, (nt, x, y))Video walkthrough
Newsletter
One sharp idea, every week
System design and interview prep — short enough to finish.
No spam. Unsubscribe anytime.
Practice
Same difficulty — related problems to reinforce the pattern.